Approximate MPC with CSTR#
In this Jupyter Notebook, we illustrate the example Approximate MPC with CSTR.
This example is an extension of the CSTR example and consists of three modules: template_model.py, which describes the system model; template_mpc.py, which defines the settings for the controller we want to approximate; and template_simulator.py, which sets the parameters for the simulator. In the main.py file, we introduce the concept of approximate MPC by generating training data, training on that data, and finally performing a closed-loop evaluation.
In the following sections, each part is presented. We begin by importing basic modules and do-mpc.
[1]:
%%capture
import torch
from casadi.tools import *
import sys
import os

# Add do_mpc to path. This is not necessary if it was installed via pip
rel_do_mpc_path = os.path.join('..', '..','..')
sys.path.append(rel_do_mpc_path)

# Import do_mpc package:
import do_mpc


import matplotlib.pyplot as plt
Model#
In the following we will present the configuration, setup and connection between these blocks, starting with the model. The considered model of the CSTR is continuous and has 4 states and 2 control inputs. The model is initiated by:
[2]:
model_type = 'continuous' # either 'discrete' or 'continuous'
model = do_mpc.model.Model(model_type)
States and control inputs#
The four states are concentration of reactant A (\(C_{\text{A}}\)), the concentration of reactant B (\(C_{\text{B}}\)), the temperature inside the reactor (\(T_{\text{R}}\)) and the temperature of the cooling jacket (\(T_{\text{K}}\)):
[3]:
# States struct (optimization variables):
C_a = model.set_variable(var_type='_x', var_name='C_a', shape=(1,1))
C_b = model.set_variable(var_type='_x', var_name='C_b', shape=(1,1))
T_R = model.set_variable(var_type='_x', var_name='T_R', shape=(1,1))
T_K = model.set_variable(var_type='_x', var_name='T_K', shape=(1,1))
The control inputs are the feed \(F\) and the heat flow \(\dot{Q}\):
[4]:
# Input struct (optimization variables):
F = model.set_variable(var_type='_u', var_name='F')
Q_dot = model.set_variable(var_type='_u', var_name='Q_dot')
ODE and parameters#
The system model is described by the ordinary differential equation:
\begin{align} \dot{C}_{\text{A}} &= F \cdot (C_{\text{A},0} - C_{\text{A}}) - k_1 \cdot C_{\text{A}} - k_3 \cdot C_{\text{A}}^2, \\ \dot{C}_{\text{B}} &= -F \cdot C_{\text{B}} + k_1 \cdot C_{\text{A}} - k_2 \cdot C_{\text{B}}, \\ \dot{T}_{\text{R}} &= \frac{k_1 \cdot C_{\text{A}} \cdot H_{\text{R},ab} + k_2 \cdot C_{\text{B}} \cdot H_{\text{R},bc} + k_3 \cdot C_{\text{A}}^2 \cdot H_{\text{R},ad}} {-\rho \cdot c_p}\\ &+ F \cdot (T_{\text{in}} - T_{\text{R}}) + \frac{K_w \cdot A_{\text{R}} \cdot(T_{\text{K}}-T_{\text{R}})}{\rho \cdot c_p \cdot V_{\text{R}}}, \\ \dot{T}_{\text{K}} &= \frac{\dot{Q} + K_w \cdot A_{\text{R}} \cdot T_{\text{dif}}}{m_k \cdot C_{p,k}}, \end{align}
where
\begin{align} k_1 &= \beta \cdot k_{0,\text{ab}} \cdot \exp\left(\frac{-E_{\text{A},\text{ab}}}{T_{\text{R}}+273.15}\right), \\ k_2 &= k_{0,\text{bc}} \cdot \exp \left( \frac{-E_{\text{A},\text{bc}}}{T_{\text{R}}+273.15} \right), \\ k_3 &= k_{0,\text{ad}} \cdot \exp \left( \frac{-\alpha \cdot E_{\text{A},\text{ad}}}{T_{\text{R}}+273.15} \right). \end{align}
[5]:
# Certain parameters
K0_ab = 1.287e12 # K0 [h^-1]
K0_bc = 1.287e12 # K0 [h^-1]
K0_ad = 9.043e9 # K0 [l/mol.h]
R_gas = 8.3144621e-3 # Universal gas constant
E_A_ab = 9758.3*1.00 #* R_gas# [kj/mol]
E_A_bc = 9758.3*1.00 #* R_gas# [kj/mol]
E_A_ad = 8560.0*1.0 #* R_gas# [kj/mol]
H_R_ab = 4.2 # [kj/mol A]
H_R_bc = -11.0 # [kj/mol B] Exothermic
H_R_ad = -41.85 # [kj/mol A] Exothermic
Rou = 0.9342 # Density [kg/l]
Cp = 3.01 # Specific Heat capacity [kj/Kg.K]
Cp_k = 2.0 # Coolant heat capacity [kj/kg.k]
A_R = 0.215 # Area of reactor wall [m^2]
V_R = 10.01 #0.01 # Volume of reactor [l]
m_k = 5.0 # Coolant mass[kg]
T_in = 130.0 # Temp of inflow [Celsius]
K_w = 4032.0 # [kj/h.m^2.K]
C_A0 = (5.7+4.5)/2.0*1.0 # Concentration of A in input Upper bound 5.7 lower bound 4.5 [mol/l]
alpha=1
beta=1
In the next step, we formulate the \(k_i\)-s:
[6]:
# Auxiliary terms
K_1 = beta * K0_ab * exp((-E_A_ab)/((T_R+273.15)))
K_2 =  K0_bc * exp((-E_A_bc)/((T_R+273.15)))
K_3 = K0_ad * exp((-alpha*E_A_ad)/((T_R+273.15)))
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[6], line 2
      1 # Auxiliary terms
----> 2 K_1 = beta * K0_ab * exp((-E_A_ab)/((T_R+273.15)))
      3 K_2 =  K0_bc * exp((-E_A_bc)/((T_R+273.15)))
      4 K_3 = K0_ad * exp((-alpha*E_A_ad)/((T_R+273.15)))

NameError: name 'exp' is not defined
Additionally, we define an artificial variable of interest, that is not a state of the system, but will be later used for plotting:
[7]:
T_dif = model.set_expression(expr_name='T_dif', expr=T_R-T_K)
With the help of the \(k_i\)-s and \(T_{\text{dif}}\) we can define the ODEs:
[8]:
model.set_rhs('C_a', F*(C_A0 - C_a) -K_1*C_a - K_3*(C_a**2))
model.set_rhs('C_b', -F*C_b + K_1*C_a - K_2*C_b)
model.set_rhs('T_R', ((K_1*C_a*H_R_ab + K_2*C_b*H_R_bc + K_3*(C_a**2)*H_R_ad)/(-Rou*Cp)) + F*(T_in-T_R) +(((K_w*A_R)*(-T_dif))/(Rou*Cp*V_R)))
model.set_rhs('T_K', (Q_dot + K_w*A_R*(T_dif))/(m_k*Cp_k))
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[8], line 1
----> 1 model.set_rhs('C_a', F*(C_A0 - C_a) -K_1*C_a - K_3*(C_a**2))
      2 model.set_rhs('C_b', -F*C_b + K_1*C_a - K_2*C_b)
      3 model.set_rhs('T_R', ((K_1*C_a*H_R_ab + K_2*C_b*H_R_bc + K_3*(C_a**2)*H_R_ad)/(-Rou*Cp)) + F*(T_in-T_R) +(((K_w*A_R)*(-T_dif))/(Rou*Cp*V_R)))
      4 model.set_rhs('T_K', (Q_dot + K_w*A_R*(T_dif))/(m_k*Cp_k))

NameError: name 'K_1' is not defined
Finally, the model setup is complete:
[9]:
# Build the model
model.setup()
---------------------------------------------------------------------------
AssertionError                            Traceback (most recent call last)
Cell In[9], line 2
      1 # Build the model
----> 2 model.setup()

File ~/checkouts/readthedocs.org/user_builds/do-mpc/checkouts/develop/documentation/source/example_gallery/../../../do_mpc/model/_model.py:986, in Model.setup(self)
    984     self._rhs[rhs_i['var_name']] = rhs_i['expr']
    985     _x_names -= set([rhs_i['var_name']])
--> 986 assert len(_x_names) == 0, 'Definition of right hand side (rhs) is incomplete. Missing: {}. Use: set_rhs to define expressions.'.format(_x_names)
    988 var_dict_list = [self._x, self._w, self._v, self._u, self._z, self._p, self._tvp]
    989 sym_struct_list = [_x, _w, _v, _u, _z, _p, _tvp]

AssertionError: Definition of right hand side (rhs) is incomplete. Missing: {'C_a', 'T_R', 'C_b', 'T_K'}. Use: set_rhs to define expressions.
Controller#
Next, the model predictive controller is configured. This is needed as the approximate MPC is a supervised training approach, where the training data is generated by the MPC. Therefore, the MPC and the model specifies the behavior of the approximate MPC. First, one member of the mpc class is generated with the prediction model defined above:
[10]:
mpc = do_mpc.controller.MPC(model)
---------------------------------------------------------------------------
AssertionError                            Traceback (most recent call last)
Cell In[10], line 1
----> 1 mpc = do_mpc.controller.MPC(model)

File ~/checkouts/readthedocs.org/user_builds/do-mpc/checkouts/develop/documentation/source/example_gallery/../../../do_mpc/controller/_mpc.py:149, in MPC.__init__(self, model, settings)
    144 def __init__(self, model: Union[do_mpc.model.Model, do_mpc.model.LinearModel],
    145              settings: Optional[MPCSettings] = None):
    147     self.model = model
--> 149     assert model.flags['setup'] == True, 'Model for MPC was not setup. After the complete model creation call model.setup().'
    150     self.data = do_mpc.data.MPCData(self.model)
    151     self.data.dtype = 'MPC'

AssertionError: Model for MPC was not setup. After the complete model creation call model.setup().
We choose the prediction horizon n_horizon, set the robust horizon n_robust to 0. It is possible to use the approximate MPC for robust MPC, but in its current only open-loop sampling can be used as a sampling strategy for the robust MPC. The time step t_step is set to 0.005h and parameters of the applied discretization scheme orthogonal collocation are as seen below:
[11]:
# Set settings of MPC:
mpc.settings.n_horizon = 20
mpc.settings.n_robust = 0
mpc.settings.open_loop = 0
mpc.settings.t_step = 0.005
mpc.settings.state_discretization = 'collocation'
mpc.settings.collocation_type = 'radau'
mpc.settings.collocation_deg = 2
mpc.settings.collocation_ni = 1
mpc.settings.store_full_solution = True
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[11], line 2
      1 # Set settings of MPC:
----> 2 mpc.settings.n_horizon = 20
      3 mpc.settings.n_robust = 0
      4 mpc.settings.open_loop = 0
      5 mpc.settings.t_step = 0.005

NameError: name 'mpc' is not defined
Because the magnitude of the states and inputs is very different, we introduce scaling factors:
[12]:
mpc.scaling['_x', 'T_R'] = 100
mpc.scaling['_x', 'T_K'] = 100
mpc.scaling['_u', 'Q_dot'] = 2000
mpc.scaling['_u', 'F'] = 100
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[12], line 1
----> 1 mpc.scaling['_x', 'T_R'] = 100
      2 mpc.scaling['_x', 'T_K'] = 100
      3 mpc.scaling['_u', 'Q_dot'] = 2000
      4 mpc.scaling['_u', 'F'] = 100

NameError: name 'mpc' is not defined
Objective#
The goal of the CSTR is to obtain a mixture with a concentration of \(C_{\text{B,ref}} = 0.6\) mol/l. Additionally, we add a penalty on input changes for both control inputs, to obtain a smooth control performance.
[13]:
mterm = (model.x['C_b'] - 0.6)**2+(model.x['C_a'] - 0.7)**2
lterm = (model.x['C_b'] - 0.6)**2+(model.x['C_a'] - 0.7)**2

mpc.set_objective(mterm=mterm, lterm=lterm)

mpc.set_rterm(F=0.1, Q_dot = 1e-3)
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[13], line 4
      1 mterm = (model.x['C_b'] - 0.6)**2+(model.x['C_a'] - 0.7)**2
      2 lterm = (model.x['C_b'] - 0.6)**2+(model.x['C_a'] - 0.7)**2
      3
----> 4 mpc.set_objective(mterm=mterm, lterm=lterm)
      5
      6 mpc.set_rterm(F=0.1, Q_dot = 1e-3)

NameError: name 'mpc' is not defined
Constraints#
In the next step, the constraints of the control problem are set. In this case, there are only upper and lower bounds for each state and the input:
[14]:
# lower bounds of the states
mpc.bounds['lower', '_x', 'C_a'] = 0.1
mpc.bounds['lower', '_x', 'C_b'] = 0.1
mpc.bounds['lower', '_x', 'T_R'] = 50
mpc.bounds['lower', '_x', 'T_K'] = 50

# upper bounds of the states
mpc.bounds['upper', '_x', 'C_a'] = 2
mpc.bounds['upper', '_x', 'C_b'] = 2
mpc.bounds['upper', '_x', 'T_R'] = 140
mpc.bounds['upper', '_x', 'T_K'] = 140

# lower bounds of the inputs
mpc.bounds['lower', '_u', 'F'] = 5
mpc.bounds['lower', '_u', 'Q_dot'] = -8500

# upper bounds of the inputs
mpc.bounds['upper', '_u', 'F'] = 100
mpc.bounds['upper', '_u', 'Q_dot'] = 0.0
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[14], line 2
      1 # lower bounds of the states
----> 2 mpc.bounds['lower', '_x', 'C_a'] = 0.1
      3 mpc.bounds['lower', '_x', 'C_b'] = 0.1
      4 mpc.bounds['lower', '_x', 'T_R'] = 50
      5 mpc.bounds['lower', '_x', 'T_K'] = 50

NameError: name 'mpc' is not defined
The setup of the MPC controller is concluded by:
[15]:
mpc.setup()
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[15], line 1
----> 1 mpc.setup()

NameError: name 'mpc' is not defined
Estimator#
We assume, that all states can be directly measured (state-feedback):
[16]:
estimator = do_mpc.estimator.StateFeedback(model)
---------------------------------------------------------------------------
TypeError                                 Traceback (most recent call last)
Cell In[16], line 1
----> 1 estimator = do_mpc.estimator.StateFeedback(model)

File ~/checkouts/readthedocs.org/user_builds/do-mpc/checkouts/develop/documentation/source/example_gallery/../../../do_mpc/estimator/_base.py:61, in StateFeedback.__init__(self, model)
     60 def __init__(self, model):
---> 61     super().__init__(model)

File ~/checkouts/readthedocs.org/user_builds/do-mpc/checkouts/develop/documentation/source/example_gallery/../../../do_mpc/estimator/_base.py:41, in Estimator.__init__(self, model)
     39 def __init__(self, model:Union[do_mpc.model.Model,do_mpc.model.LinearModel]):
     40     self.model = model
---> 41     do_mpc.model.IteratedVariables.__init__(self)
     43     assert model.flags['setup'] == True, 'Model for estimator was not setup. After the complete model creation call model.setup().'
     45     self.data = do_mpc.data.Data(model)

File ~/checkouts/readthedocs.org/user_builds/do-mpc/checkouts/develop/documentation/source/example_gallery/../../../do_mpc/model/_iteratedvariables.py:40, in IteratedVariables.__init__(self)
     37 assert 'model' in self.__dict__.keys(), 'Cannot initialize variables before assigning the model to the current class instance.'
     39 # Initialize structure for initial conditions:
---> 40 self._x0 = self.model._x(0.0)
     41 self._u0 = self.model._u(0.0)
     42 self._z0 = self.model._z(0.0)

TypeError: 'dict' object is not callable
Simulator#
To create a simulator to run the approximate MPC in a closed-loop, we create an instance of the do-mpc simulator which is based on the same model:
[17]:
simulator = do_mpc.simulator.Simulator(model)
---------------------------------------------------------------------------
TypeError                                 Traceback (most recent call last)
Cell In[17], line 1
----> 1 simulator = do_mpc.simulator.Simulator(model)

File ~/checkouts/readthedocs.org/user_builds/do-mpc/checkouts/develop/documentation/source/example_gallery/../../../do_mpc/simulator.py:154, in Simulator.__init__(self, model)
    151 def __init__(self, model:do_mpc.model.Model):
    153     self.model = model
--> 154     do_mpc.model.IteratedVariables.__init__(self)
    156     assert model.flags['setup'] == True, 'Model for simulator was not setup. After the complete model creation call model.setup().'
    158     self.data = do_mpc.data.Data(model)

File ~/checkouts/readthedocs.org/user_builds/do-mpc/checkouts/develop/documentation/source/example_gallery/../../../do_mpc/model/_iteratedvariables.py:40, in IteratedVariables.__init__(self)
     37 assert 'model' in self.__dict__.keys(), 'Cannot initialize variables before assigning the model to the current class instance.'
     39 # Initialize structure for initial conditions:
---> 40 self._x0 = self.model._x(0.0)
     41 self._u0 = self.model._u(0.0)
     42 self._z0 = self.model._z(0.0)

TypeError: 'dict' object is not callable
For the simulation, we use the same time step t_step as for the optimizer:
[18]:
params_simulator = {
        'integration_tool': 'cvodes',
        'abstol': 1e-10,
        'reltol': 1e-10,
        't_step': 0.005
    }

simulator.set_param(**params_simulator)
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[18], line 8
      4         'reltol': 1e-10,
      5         't_step': 0.005
      6     }
      7
----> 8 simulator.set_param(**params_simulator)

NameError: name 'simulator' is not defined
To finish the configuration of the simulator, call:
[19]:
simulator.setup()
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[19], line 1
----> 1 simulator.setup()

NameError: name 'simulator' is not defined
Initialization of the MPC and Simulator#
For the initialization of the MPC configured for the CSTR, we inspect the file main.py. We define the initial state of the system and set it for all parts of the closed-loop configuration:
[20]:
# Set the initial state of mpc and simulator:
C_a_0 = 0.8 # This is the initial concentration inside the tank [mol/l]
C_b_0 = 0.5 # This is the controlled variable [mol/l]
T_R_0 = 134.14 #[C]
T_K_0 = 130.0 #[C]
x0 = np.array([C_a_0, C_b_0, T_R_0, T_K_0]).reshape(-1,1)
u0=np.array([[5],[0]])

# pushing to class
mpc.u0=u0
mpc.x0 = x0
simulator.x0 = x0
mpc.set_initial_guess()
simulator.set_initial_guess()
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[20], line 6
      2 C_a_0 = 0.8 # This is the initial concentration inside the tank [mol/l]
      3 C_b_0 = 0.5 # This is the controlled variable [mol/l]
      4 T_R_0 = 134.14 #[C]
      5 T_K_0 = 130.0 #[C]
----> 6 x0 = np.array([C_a_0, C_b_0, T_R_0, T_K_0]).reshape(-1,1)
      7 u0=np.array([[5],[0]])
      8
      9 # pushing to class

NameError: name 'np' is not defined
Approximate MPC#
So far, we have only initialized our model, the MPC and the Simulator, which is like the usage of a MPC for controlling the system. In the next steps we must configure our approximate MPC, the Sampler for generating training data and the Trainer for training the Approximate MPC. These three classes are the main components of the Approximate MPC. As it is standard in do-mpc, each of these classes can be configured using the settings of the respective class. After calling setup() the instance of the class is ready to be used. First, the Approximate MPC is configured. One member of the ApproximateMPC class is generated which is initialized with the MPC class defined above:
[21]:
approx_mpc = do_mpc.approximateMPC.ApproxMPC(mpc)
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[21], line 1
----> 1 approx_mpc = do_mpc.approximateMPC.ApproxMPC(mpc)

NameError: name 'mpc' is not defined
Appropriate sizes for number of hidden layers n_hidden_layers and number of neurons per layer n_neurons are chosen in this example using the settings class. Note that default parameters of each settings parameter are provided.:
[22]:
approx_mpc.settings.n_hidden_layers = 1
approx_mpc.settings.n_neurons = 50
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[22], line 1
----> 1 approx_mpc.settings.n_hidden_layers = 1
      2 approx_mpc.settings.n_neurons = 50

NameError: name 'approx_mpc' is not defined
Other setting parameters for the approximate MPC include the activation function and the device on which the approximate MPC should run. The setup of the Approximate MPC controller is concluded by:
[23]:
approx_mpc.setup()
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[23], line 1
----> 1 approx_mpc.setup()

NameError: name 'approx_mpc' is not defined
Sampler#
Next, a Sampler is configured. This class is used to generate training data for Approximate MPC. It uses the already established sampling planner of do-mpc, son in case you want to take a deep dive into generating data with do-mpc, you can revisit the respective example. This class also needs to be initialized with the MPC class as it uses the MPC to generate the training data.
[24]:
sampler = do_mpc.approximateMPC.AMPCSampler(mpc)
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[24], line 1
----> 1 sampler = do_mpc.approximateMPC.AMPCSampler(mpc)

NameError: name 'mpc' is not defined
Next, the Sampler settings are configured. Currently, we support two sampling approaches, the open-loop standard sampling, where n_samples random data is sampled within the bounds of the MPC. The closed_loop_flag can be used to use a closed-loop sampling approach where closed loop trajectories of the length trajectory_length. Note that now **n_samples*trajectory_length** sampling data points are generated. In fact, in this example we do open loop sampling by setting
trajectory_length=1 but are showing how to use the closed loop sampling method in general. Again, these parameters are set through the settings class.
[25]:
sampler.settings.closed_loop_flag = True
sampler.settings.trajectory_length = 1
sampler.settings.n_samples = 10000
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[25], line 1
----> 1 sampler.settings.closed_loop_flag = True
      2 sampler.settings.trajectory_length = 1
      3 sampler.settings.n_samples = 10000

NameError: name 'sampler' is not defined
The number of samples is a mandatory setting. The other one is the name of the dataset. You can also set the directory in which this dataset is stored which is optional
[26]:
data_dir= './sampling_notebook'
sampler.settings.data = data_dir
dataset_name = "my_dataset"
sampler.settings.dataset_name = dataset_name
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[26], line 2
      1 data_dir= './sampling_notebook'
----> 2 sampler.settings.data = data_dir
      3 dataset_name = "my_dataset"
      4 sampler.settings.dataset_name = dataset_name

NameError: name 'sampler' is not defined
The setup of the Sampler class is concluded by:
[27]:
sampler.setup()
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[27], line 1
----> 1 sampler.setup()

NameError: name 'sampler' is not defined
The Sampler is now used to generate the sample data on which the ApproximateMPC will be trained further. for this a default sampling plan is used. This iteratively calculates the training data, so depending on n_samples and the complexity of the MPC controller, it might take a while. (The output of the MPC is suppressed with the magic command %%capture) For this example we have already generated the data
[28]:
%%capture
#sampler.default_sampling()
Trainer#
Next, a Trainer is configured. The Trainer is used to train the approximate MPC on the generated training data. Therefore, the Trainer is initialized with the ApproximateMPC class:
[29]:
trainer = do_mpc.approximateMPC.Trainer(approx_mpc)
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[29], line 1
----> 1 trainer = do_mpc.approximateMPC.Trainer(approx_mpc)

NameError: name 'approx_mpc' is not defined
Next the trainer setting parameters are configured. Make sure to set the right direction for the training data, which is done by setting the data_dir and the right name of the dataset.:
[30]:
trainer.settings.data_dir = data_dir
trainer.settings.dataset_name = dataset_name
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[30], line 1
----> 1 trainer.settings.data_dir = data_dir
      2 trainer.settings.dataset_name = dataset_name

NameError: name 'trainer' is not defined
We now set the hyper-parameters for the training of the approximate MPC such as n_epochs. The Trainer also can use the learning rate scheduler of Pytorch for which the parameters can be set with the scheduler_settings. This can improve the training performance when hitting a plateau, by reducing the learning rate, so that the loss does not oscillate around the optimal point. It is set to False as we do not need it for this simple example
[31]:
trainer.settings.n_epochs = 3000
trainer.settings.scheduler_flag = False
trainer.scheduler_settings.cooldown = 0
trainer.scheduler_settings.patience = 50
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[31], line 1
----> 1 trainer.settings.n_epochs = 3000
      2 trainer.settings.scheduler_flag = False
      3 trainer.scheduler_settings.cooldown = 0
      4 trainer.scheduler_settings.patience = 50

NameError: name 'trainer' is not defined
To display and save the performance of the training, the following flags may be set:
[32]:
trainer.settings.show_fig =True
trainer.settings.save_fig = True
trainer.settings.save_history = True
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[32], line 1
----> 1 trainer.settings.show_fig =True
      2 trainer.settings.save_fig = True
      3 trainer.settings.save_history = True

NameError: name 'trainer' is not defined
The location where the samples data is stored is provided with results_dir:
[33]:
trainer.settings.results_dir = './training_notebook'
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[33], line 1
----> 1 trainer.settings.results_dir = './training_notebook'

NameError: name 'trainer' is not defined
Finally, the trainer is setup:
[34]:
trainer.setup()
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[34], line 1
----> 1 trainer.setup()

NameError: name 'trainer' is not defined
The training process is initiated:
[35]:
%%capture
torch.manual_seed(42)
trainer.default_training()
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[36], line 2
      1 torch.manual_seed(42)
----> 2 trainer.default_training()

NameError: name 'trainer' is not defined
Closed loop simulation#
Now all we are ready for simulating the system with the newly trained approximate MPC controller, for 50 steps. As for the MPC the make_step function of the approximate MPC is used where instead of solving an optimization problem the pre-trained neural network is evaluated. It is possible to clip the control inputs to the bounds of the MPC controller with the flag clip_to_bounds=True.
When clip_to_bounds=True, the inputs are forced to be within the set upper boundary and the set lower boundary, ensuring that no matter what, the inputs are within permissible bounds.
[36]:
sim_time = 100
approx_mpc.u0=u0
for k in range(sim_time):
    u0 = approx_mpc.make_step(x0, clip_to_bounds=True)
    y_next = simulator.make_step(u0)
    x0 = estimator.make_step(y_next)
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[36], line 2
      1 sim_time = 100
----> 2 approx_mpc.u0=u0
      3 for k in range(sim_time):
      4     u0 = approx_mpc.make_step(x0, clip_to_bounds=True)
      5     y_next = simulator.make_step(u0)

NameError: name 'u0' is not defined
Visualization#
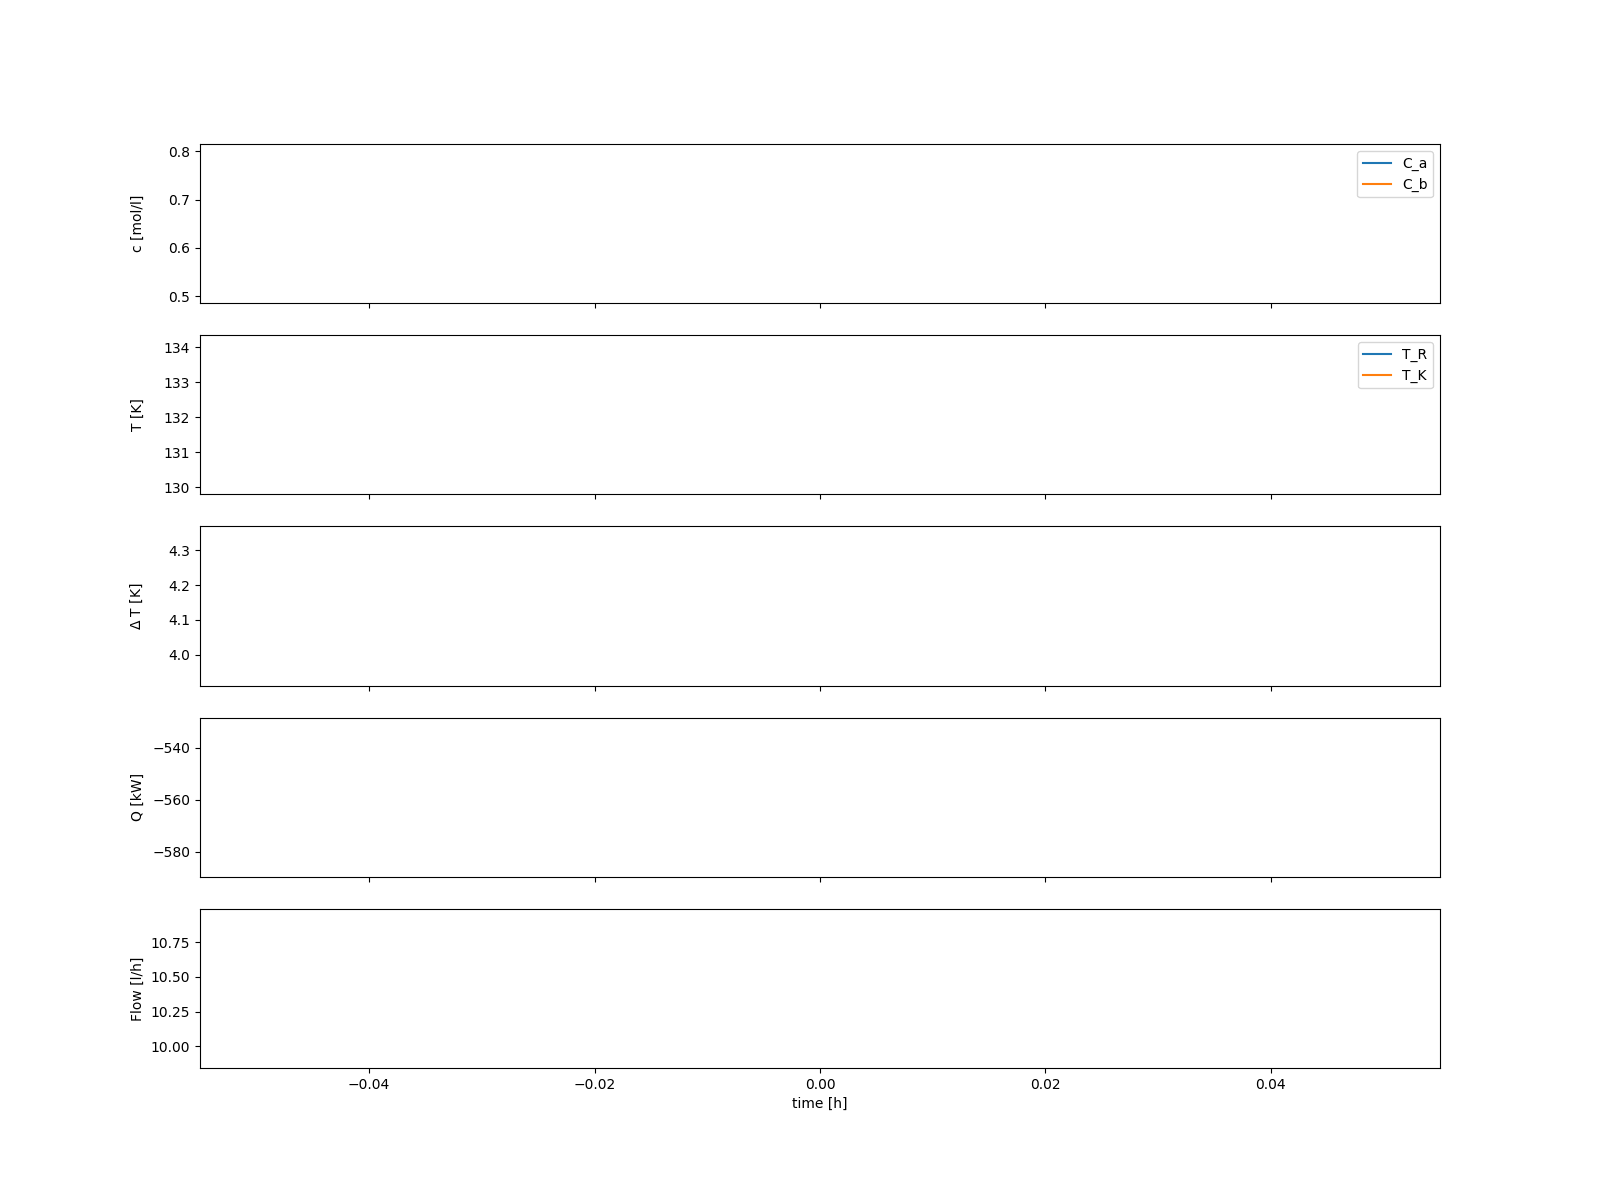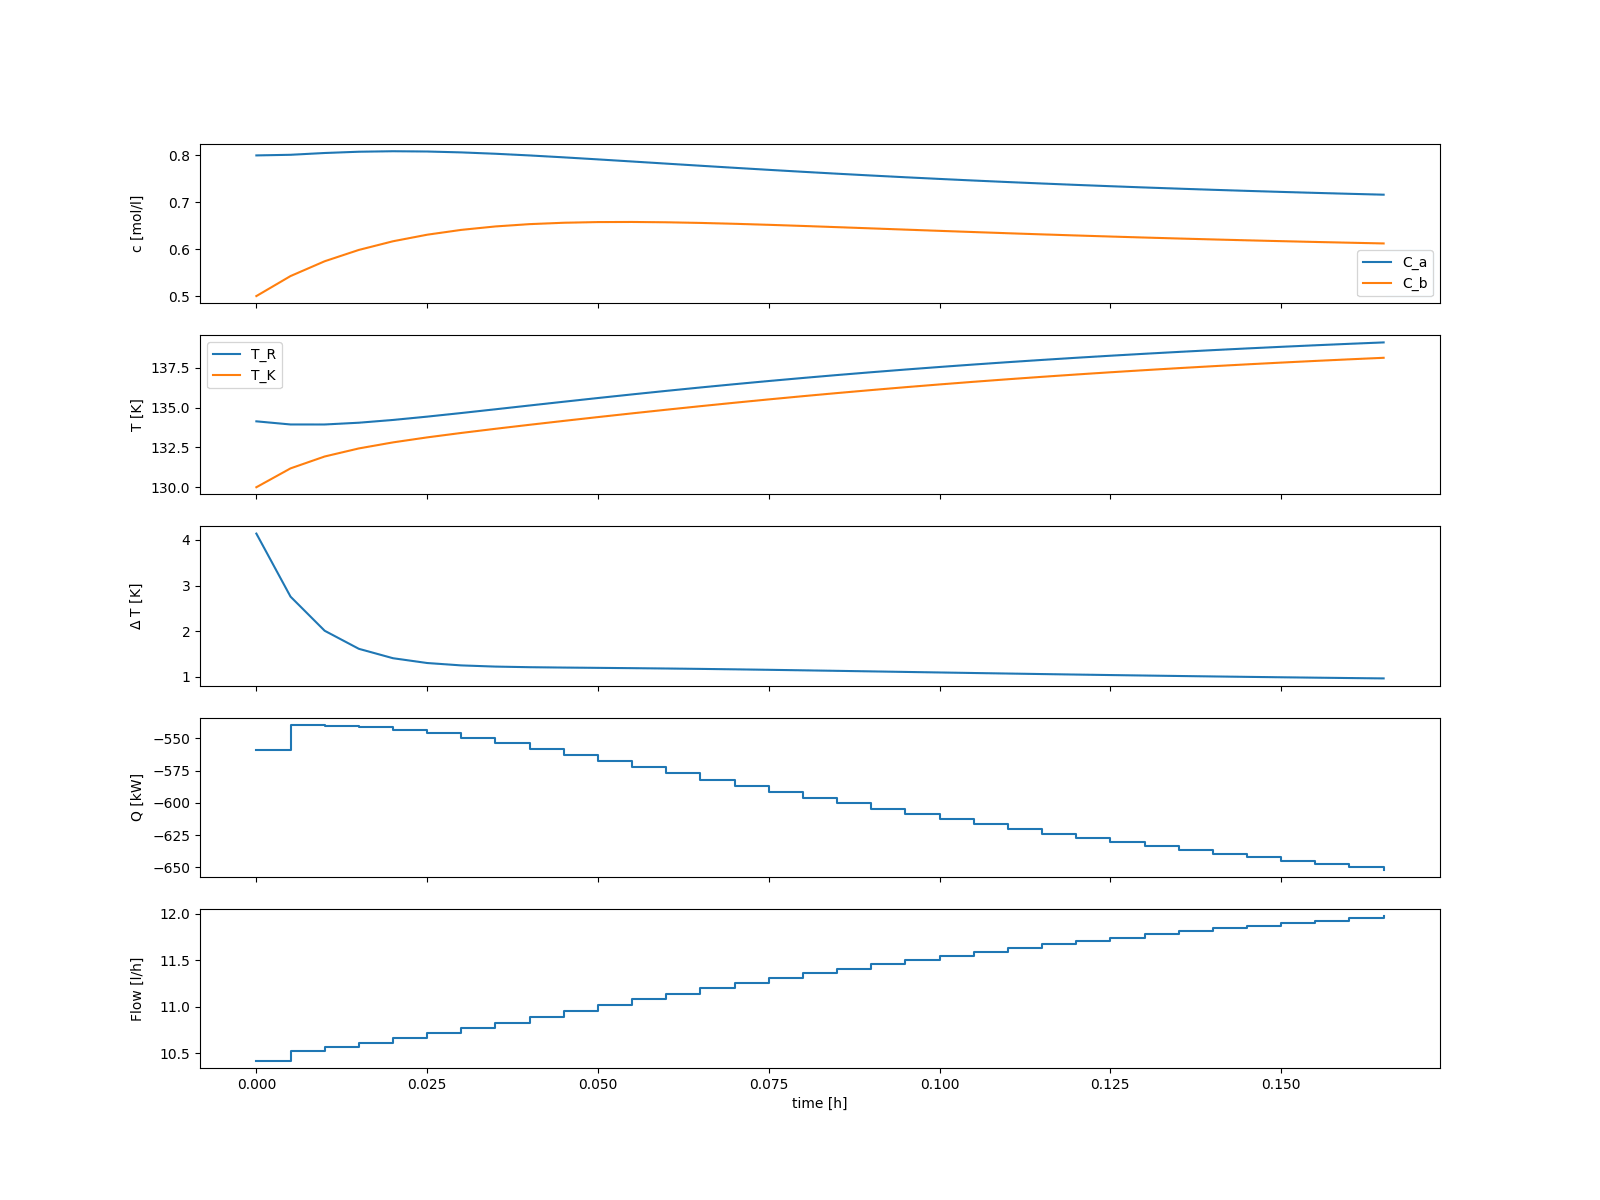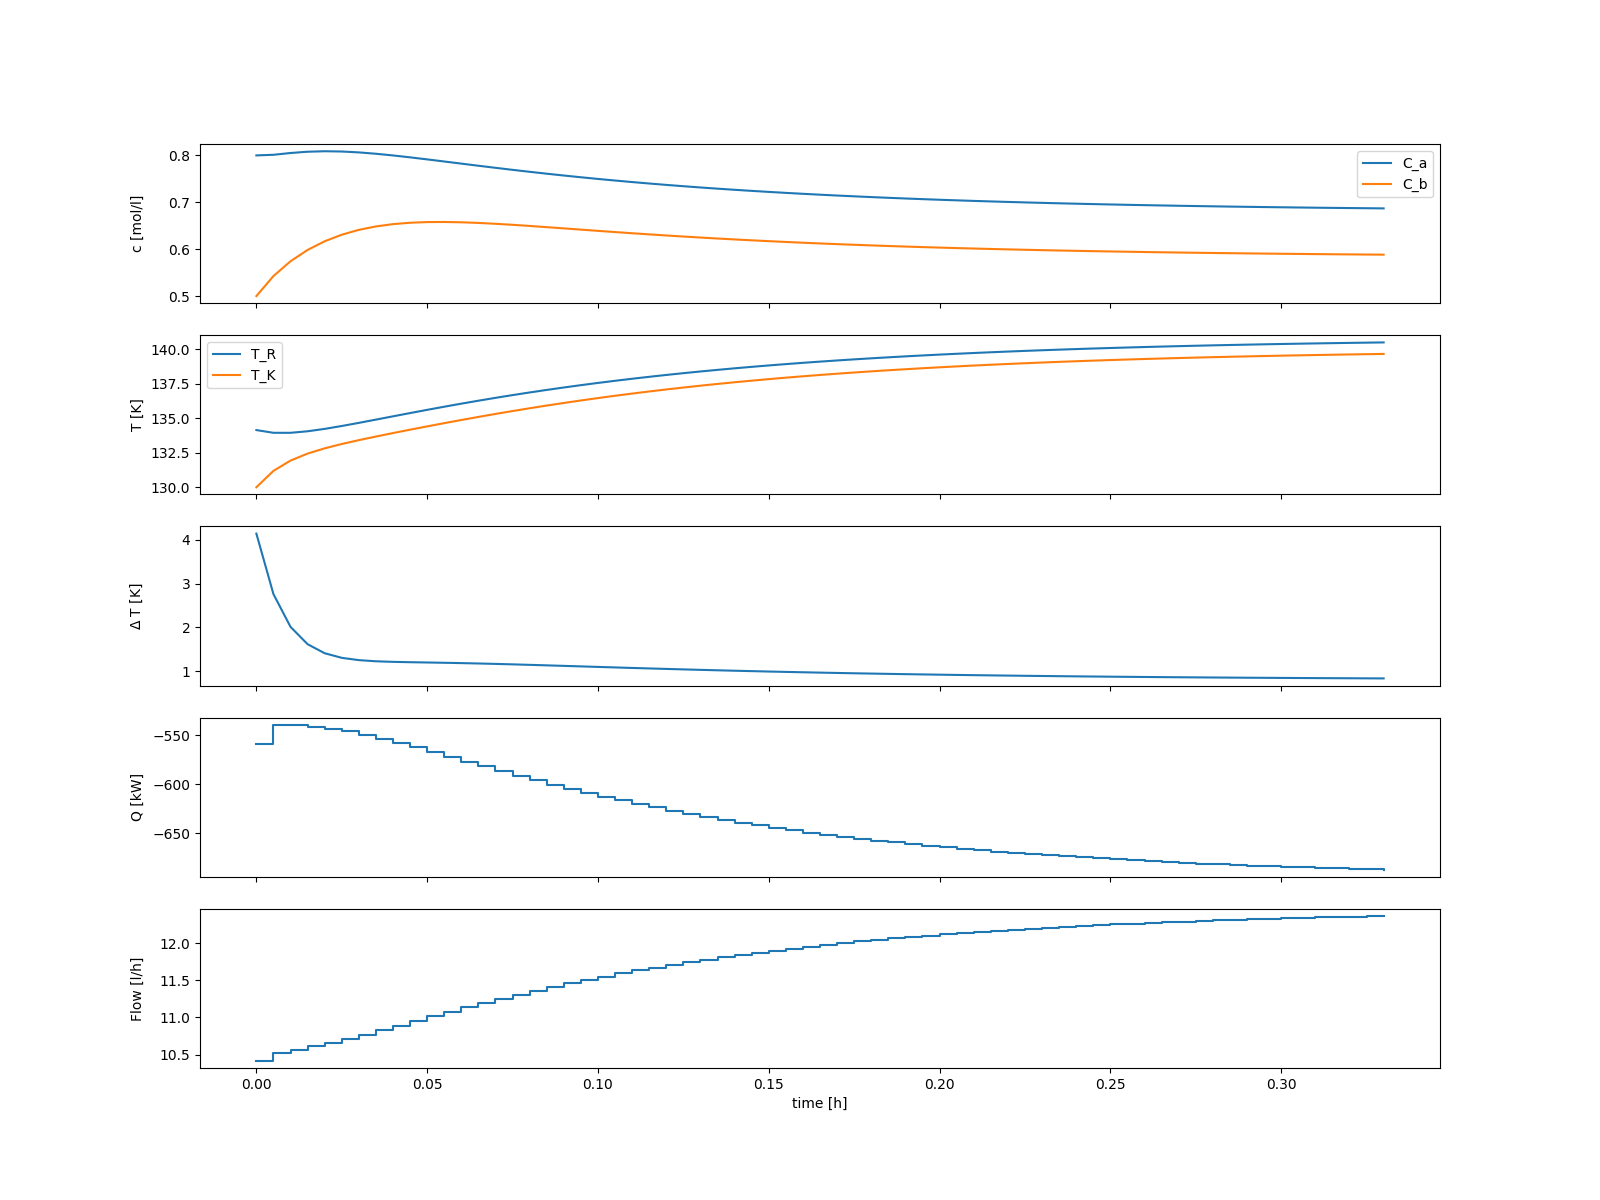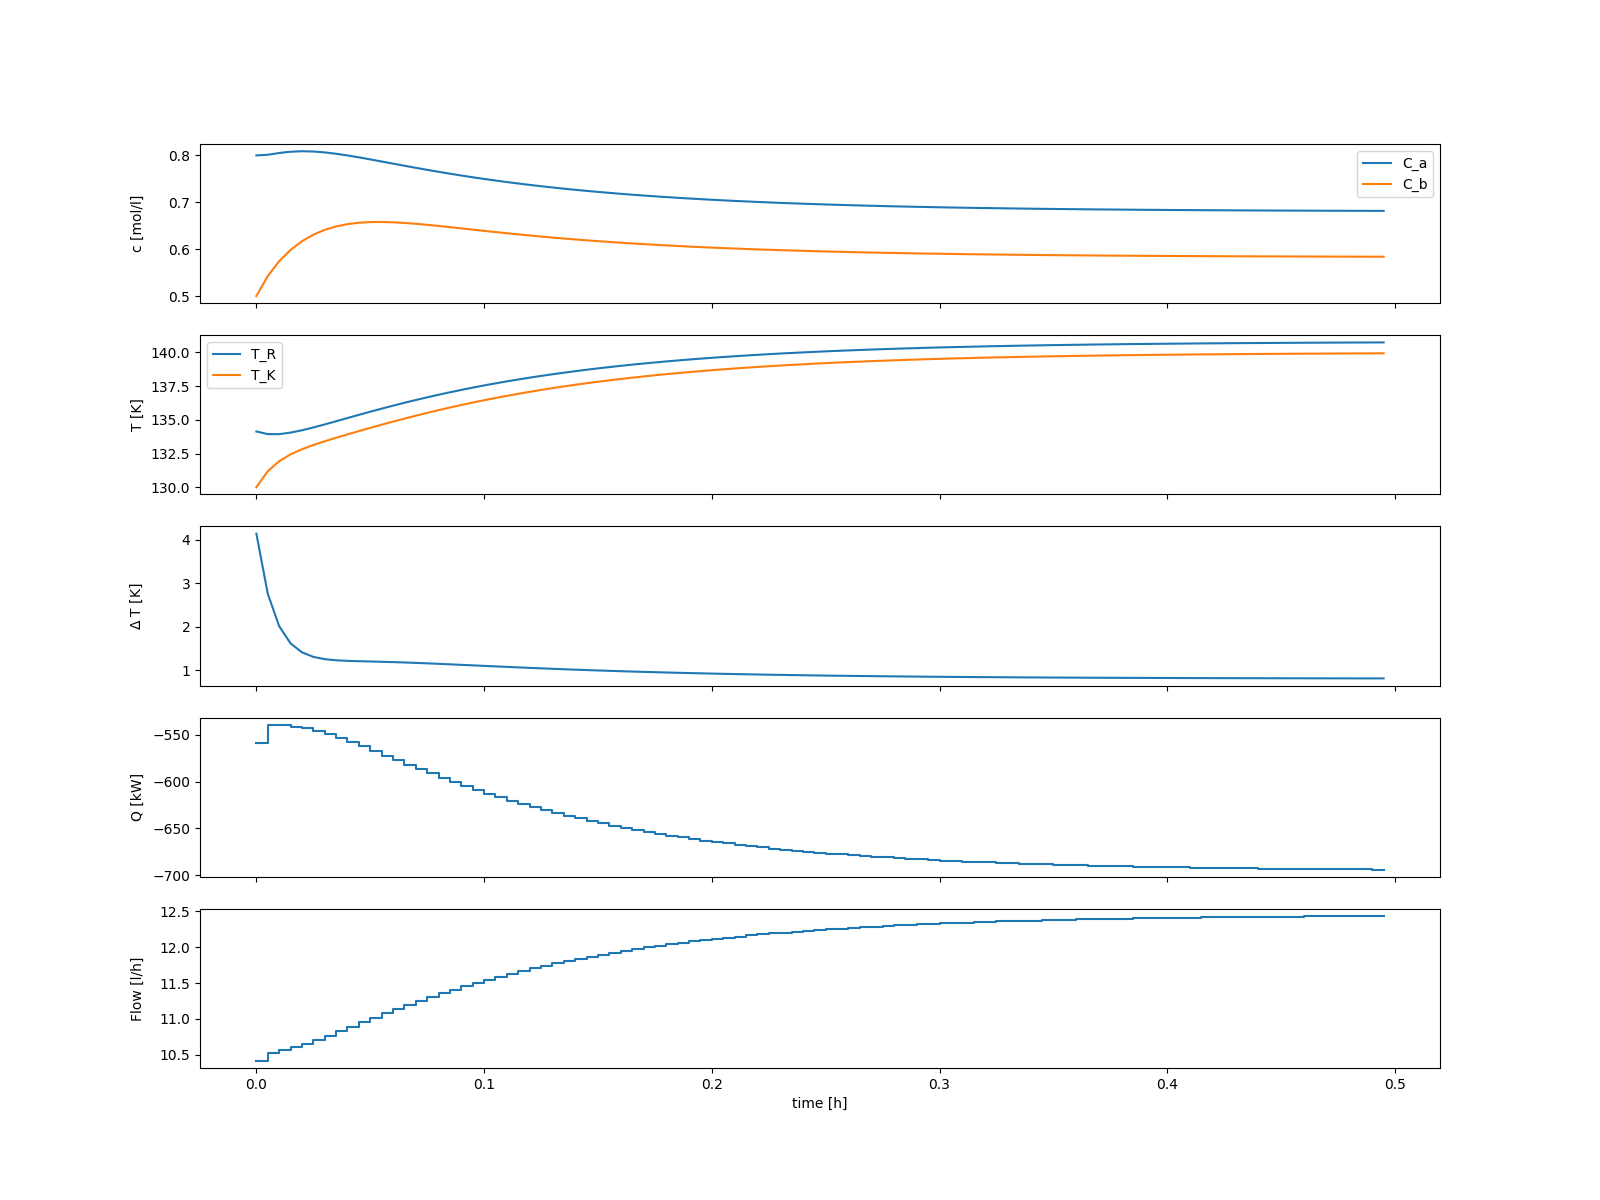
To animate the results, we first configure the do-mpc graphics object, which is initiated with the respective data object:
Here we use simulator.data, since the simulator consists of the class which stores the data which can be extracted. As a contrast, the data from the mpc class cannot be used, since in the main simulation loop, mpc class is not used.
[37]:
sim_graphics = do_mpc.graphics.Graphics(simulator.data)
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[37], line 1
----> 1 sim_graphics = do_mpc.graphics.Graphics(simulator.data)

NameError: name 'simulator' is not defined
We then create a figure, configure which lines to plot on which axis and add labels.
[38]:
import matplotlib.pyplot as plt

fig, ax = plt.subplots(5, sharex=True, figsize=(16,12))
# Configure plot:
sim_graphics.add_line(var_type='_x', var_name='C_a', axis=ax[0])
sim_graphics.add_line(var_type='_x', var_name='C_b', axis=ax[0])
sim_graphics.add_line(var_type='_x', var_name='T_R', axis=ax[1])
sim_graphics.add_line(var_type='_x', var_name='T_K', axis=ax[1])
sim_graphics.add_line(var_type='_aux', var_name='T_dif', axis=ax[2])
sim_graphics.add_line(var_type='_u', var_name='Q_dot', axis=ax[3])
sim_graphics.add_line(var_type='_u', var_name='F', axis=ax[4])
ax[0].set_ylabel('c [mol/l]')
ax[1].set_ylabel('T [K]')
ax[2].set_ylabel('$\Delta$ T [K]')
ax[3].set_ylabel('Q [kW]')
ax[4].set_ylabel('Flow [l/h]')
ax[4].set_xlabel('time [h]')
---------------------------------------------------------------------------
NameError                                 Traceback (most recent call last)
Cell In[38], line 5
      1 import matplotlib.pyplot as plt
      2
      3 fig, ax = plt.subplots(5, sharex=True, figsize=(16,12))
      4 # Configure plot:
----> 5 sim_graphics.add_line(var_type='_x', var_name='C_a', axis=ax[0])
      6 sim_graphics.add_line(var_type='_x', var_name='C_b', axis=ax[0])
      7 sim_graphics.add_line(var_type='_x', var_name='T_R', axis=ax[1])
      8 sim_graphics.add_line(var_type='_x', var_name='T_K', axis=ax[1])

NameError: name 'sim_graphics' is not defined